

Robotic Bending Cell
Integrate the press brake, robot and part handling around a validated bending process.
Discuss Your Project →Explore products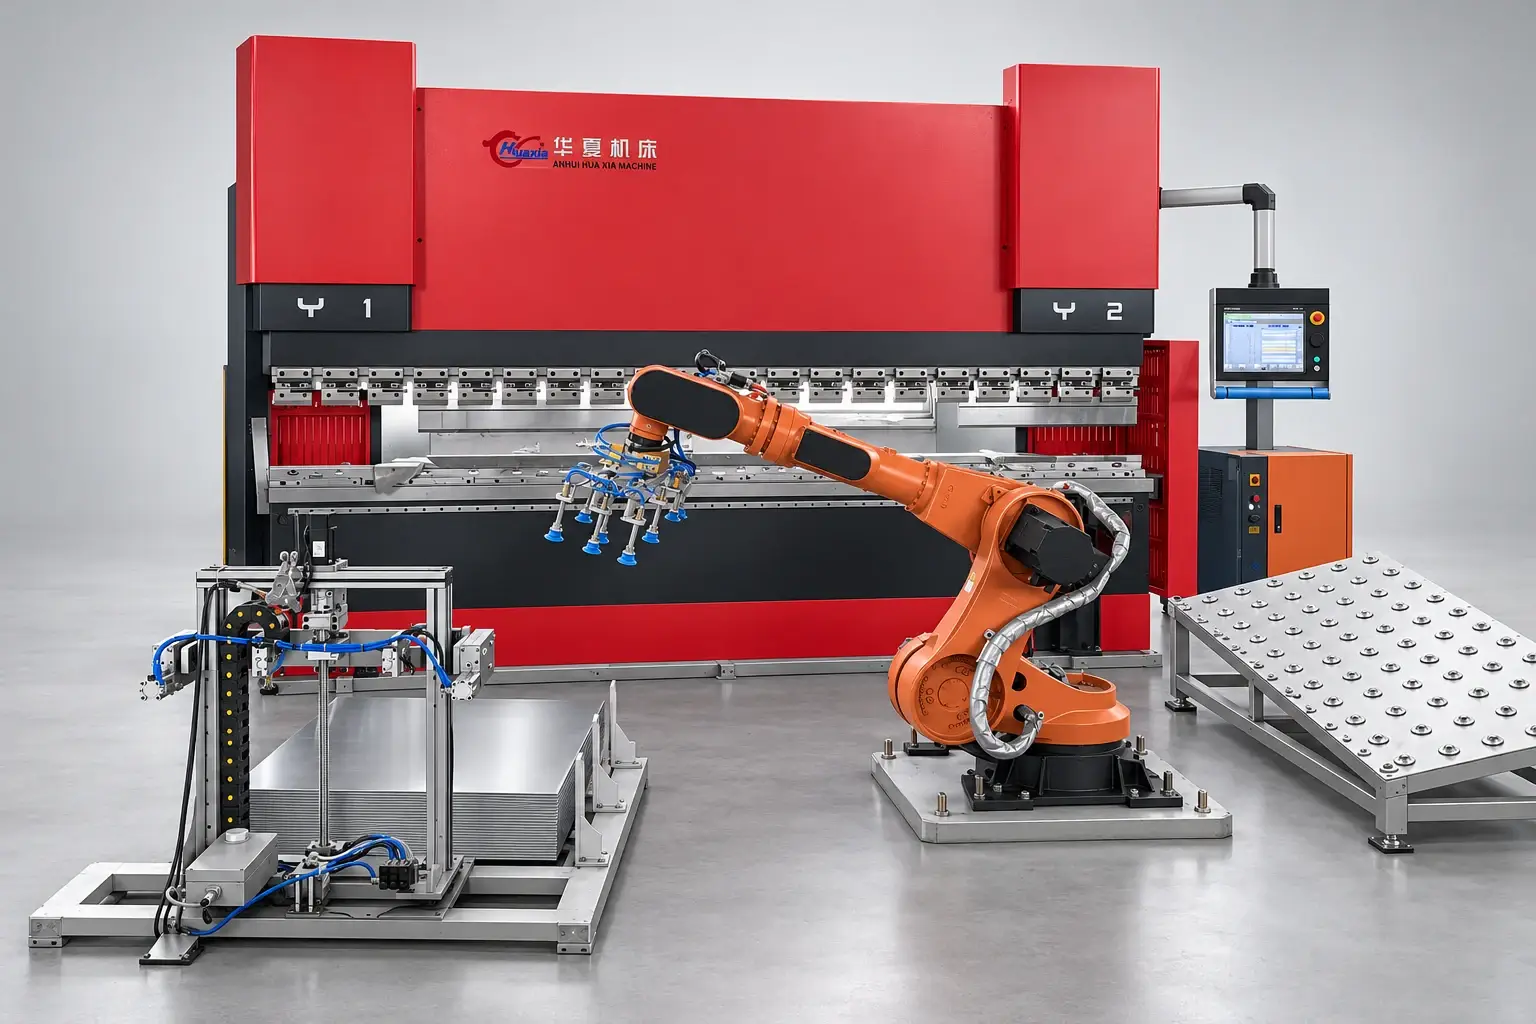
Part Feasibility
Supply the flat pattern, finished drawing, material, thickness, weight and surface requirements. Review gripper access through every bend and identify where regripping or dedicated positioning is required.
Cell Configuration
| Press brake | Working length, force, opening, stroke, tooling and control interface. |
|---|---|
| Robot and gripper | Payload, reach, work envelope, vacuum or mechanical gripping and collision clearance. |
| Handling | Blank loading, part alignment, regripping, output stacking and reject handling. |
| Operation | Batch changes, programming, guarding, maintenance access and operator training. |
Production Planning
Validate the target cycle using the complete sequence, including handling and stacking. Compare the repeatability of the part family and changeover frequency with the expected production schedule before confirming the automation scope.
Plan the right configuration
Send the material grade, minimum and maximum thickness, part dimensions, drawings, daily output target, local power supply and delivery destination. Include tooling or automation requirements so the proposal covers the complete process.
Request an Engineering Review →Browse manuals and downloads